Agentic driver for a RIGOL MSO5000 oscilloscope
Python driver, CLI and web UI for a RIGOL MSO5204 oscilloscope, with an LLM agent that turns plain-language requests into reviewable measurement plans.
Why#
Oscilloscope measurements in the lab were set up by hand on the front panel, which is slow to repeat and hard to document. I wanted every setting and capture to be scriptable, logged and reproducible, and a first test of how an AI agent can operate real lab instruments safely.
What it does#
- Instrument control over VISA (USB-TMC or LAN): identification, run, stop, single and autoscale, plus channel, timebase, trigger and acquisition settings.
- Measurements and capture: built-in measurement items, waveform capture to CSV (converted to volts and time from the waveform preamble), and screen captures.
- Three interfaces on one driver: a command-line tool for scripts, a Streamlit web UI with live plots, and raw SCPI access for debugging.
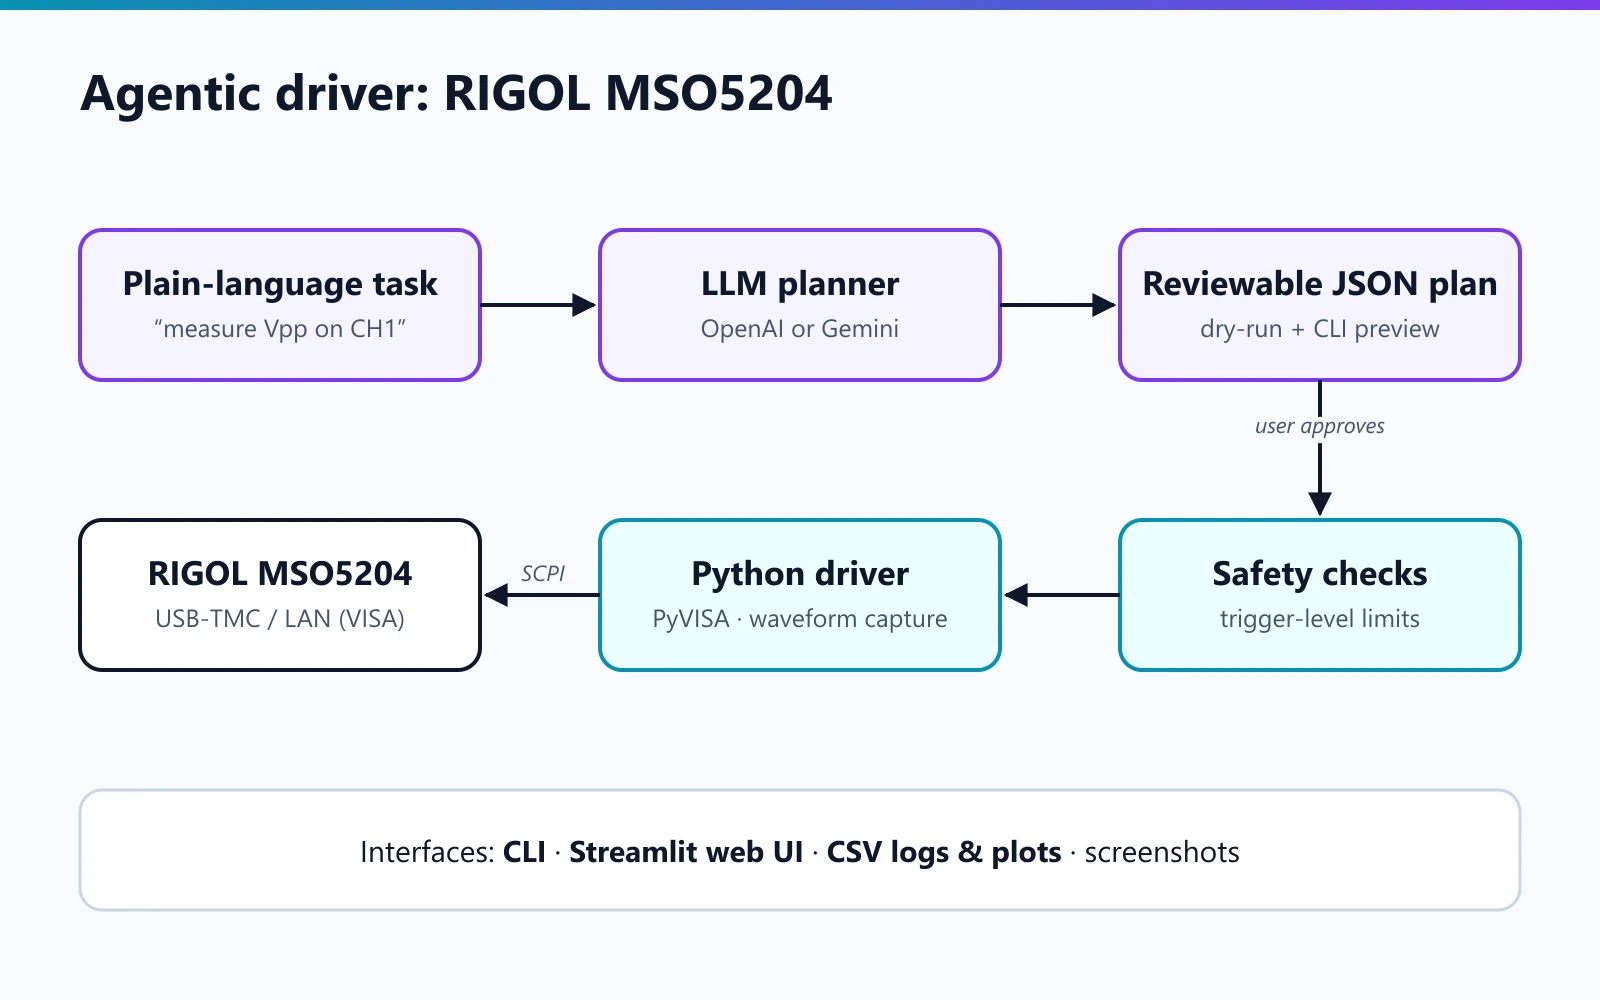
- Agentic control: an optional LLM agent (OpenAI or Gemini) translates a request such as "measure Vpp on channel 1" into an explicit JSON plan. The plan is shown with its equivalent CLI commands and only runs after the user approves it.
- Safety: limits from a YAML configuration, such as a maximum trigger level, are checked before commands reach the instrument, and the agent refuses raw SCPI commands unless the user explicitly asks for them.
How it is built#
- Driver: a Python oscilloscope class on PyVISA, sending SCPI and decoding binary waveform blocks.
- Agent: a planner that returns a constrained JSON schema of allowed actions, and an executor that validates each step and streams progress to the UI.
- Configuration: a single YAML file for the connection, defaults and safety limits.
- Documentation: user guide, CLI reference, architecture, safety and troubleshooting notes.
My role#
I designed and wrote the driver, CLI, UI and agent, and the documentation.
Code availability#
Developed at ICIQ in Prof. Julio Lloret-Fillol's group. The source code is in a private ICIQ repository and is not published here. I'm happy to discuss the design or give a demo on request.
This work feeds into the agentic-AI layer of my self-driving lab research.