Agentic driver for an EA PS2084 power supply
Python driver, CLI and web UI for an EA PS2084 power supply: smooth ramps, multi-step programs with CSV logging, and an LLM agent with dry-run plans.
Why#
Lab experiments often need a power supply to follow a precise profile (ramp up, hold, step, repeat) while recording what actually happened. Doing that by hand is error-prone and leaves no record, so I built a scriptable driver with logging and a safe agentic interface.
What it does#
- Instrument control over USB serial (SCPI): identification, status, output on/off, and voltage and current setpoints, with a recovery command for settings conflicts.
- Smooth ramps: move to a target voltage and current over a set time, hold, and log measured values to CSV.
- Multi-step programs: tables of steps written in YAML, repeated for a number of cycles, with automatic logs.
- Web UI (Streamlit): connect, ramp and run programs, with live plots of setpoints against measured values.
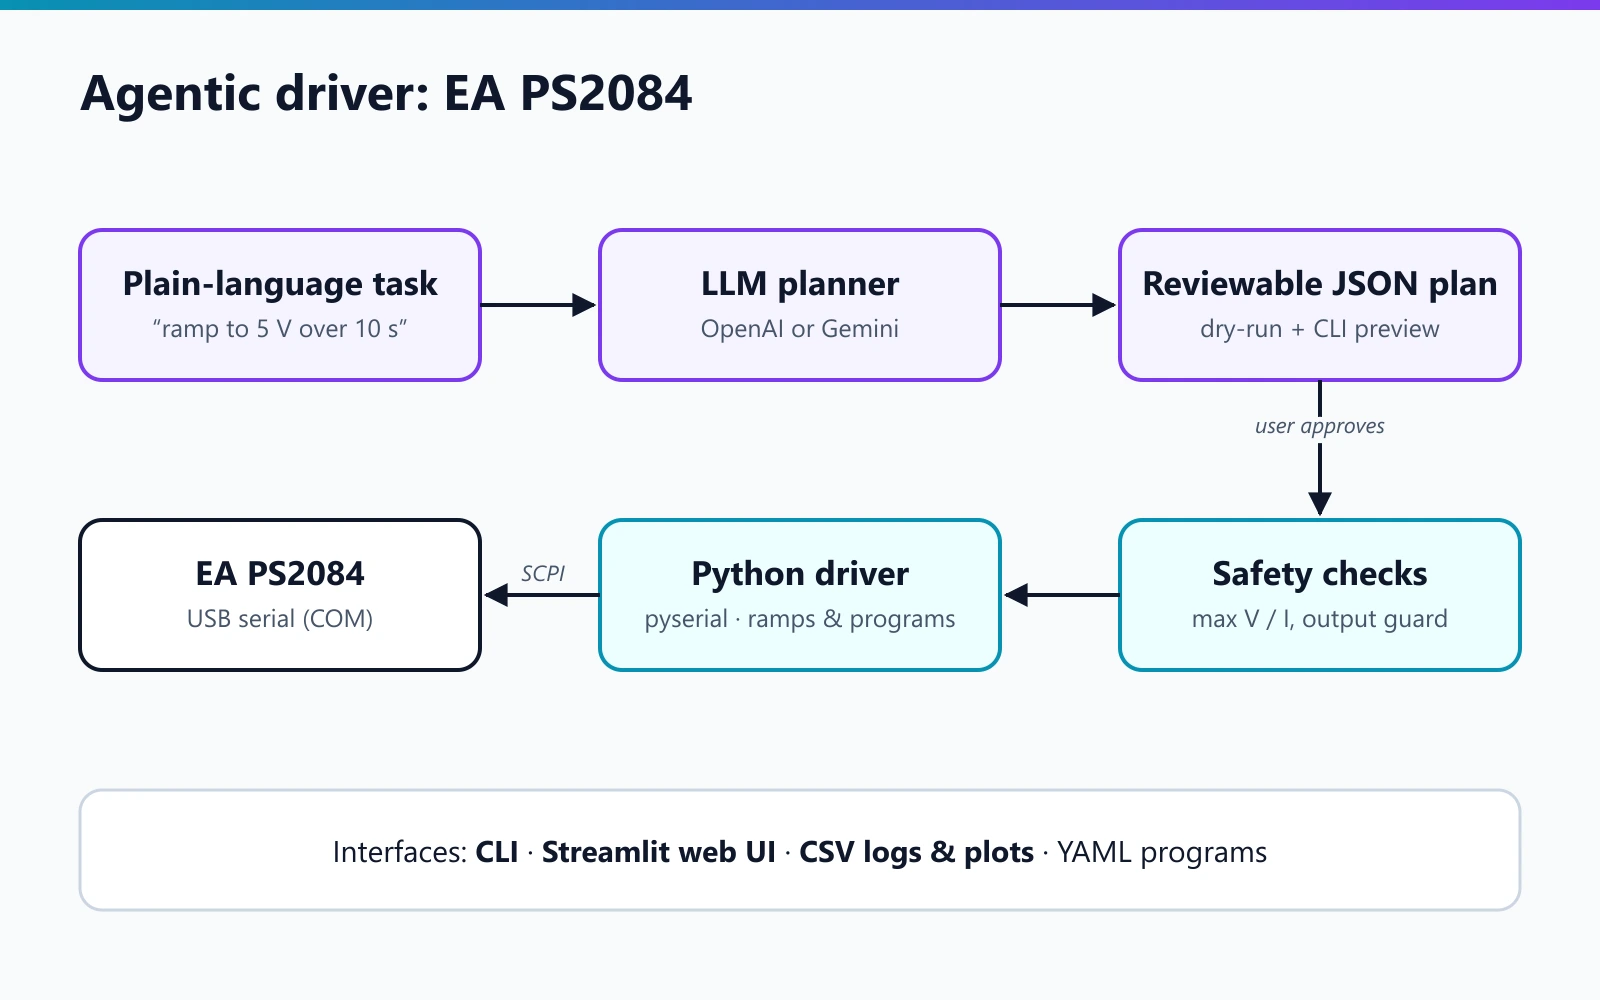
- Agentic control: an optional LLM agent (OpenAI or Gemini) turns a request such as "ramp to 5 V and 1 A over 10 seconds, hold 2 seconds" into a JSON plan. It is a dry run by default and only executes with an explicit flag or button.
- Safety: the driver enforces maximum voltage and current from the configuration, and the agent refuses to switch the output on unless the user explicitly asks for it.
How it is built#
- Driver: Python with pyserial, with SCPI command strings defined in configuration so they can be adapted to other models.
- Ramp engine: a separate module for timed ramps and programs, shared by the CLI, the UI and the agent.
- Agent: a planner with a constrained action schema, and an executor that validates and runs each step.
- Quality: a connection test, plus user, CLI, configuration, log-format and safety documentation.
My role#
I designed and wrote the driver, ramp engine, CLI, UI and agent, and the documentation.
Code availability#
Developed at ICIQ in Prof. Julio Lloret-Fillol's group. The source code is in a private ICIQ repository and is not published here. I'm happy to discuss the design or give a demo on request.
This work feeds into the agentic-AI layer of my self-driving lab research.