Research · 2022
QuadControl: a controller for multiple drones
LCIS lab · Grenoble INP Esisar
Experimental validation of a multi-drone controller using Qualisys motion capture at the LCIS laboratory.
RoboticsDronesControlPython
Overview#
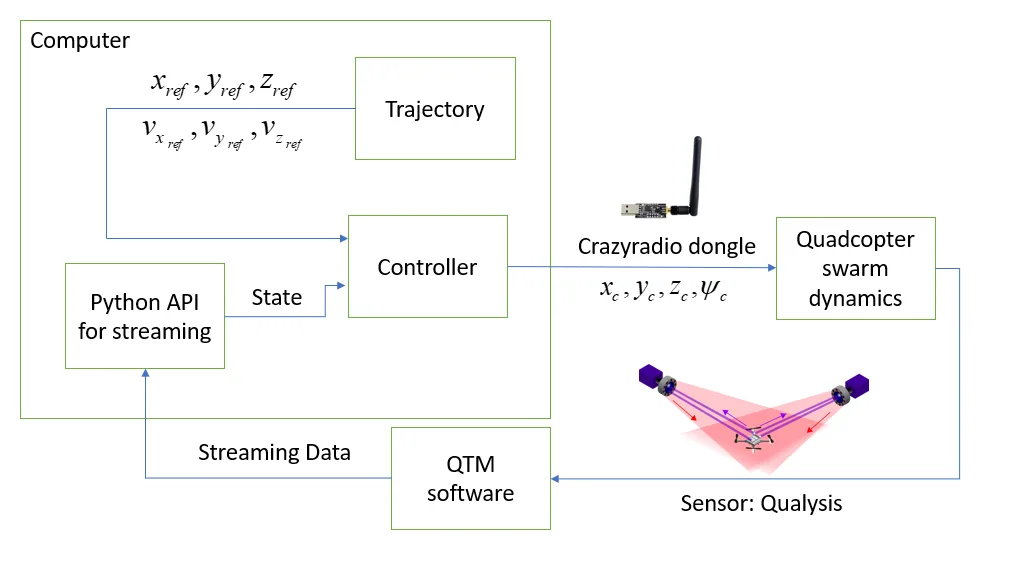
This work models a controller for a quadcopter based on the property of differential flatness, and designs the motion planning needed to fly multiple drones.
- Build a mathematical model of the drone's kinematics.
- Set up a simulation environment to design an LQR trajectory-tracking controller.
- Validate the controller on Crazyflie drones, using Qualisys Track Manager (QTM) motion capture, and assess trajectory tracking for a single drone and for a swarm.
An innovation project at Grenoble INP Esisar with Cong Khanh Dinh, Nada Hamdouni and Clarice Sofia Henrique Soares.
LCIS lab, Valence, France.