Quadrupedal insect robot
Four-legged walking robot inspired by insect gait.
Introduction#
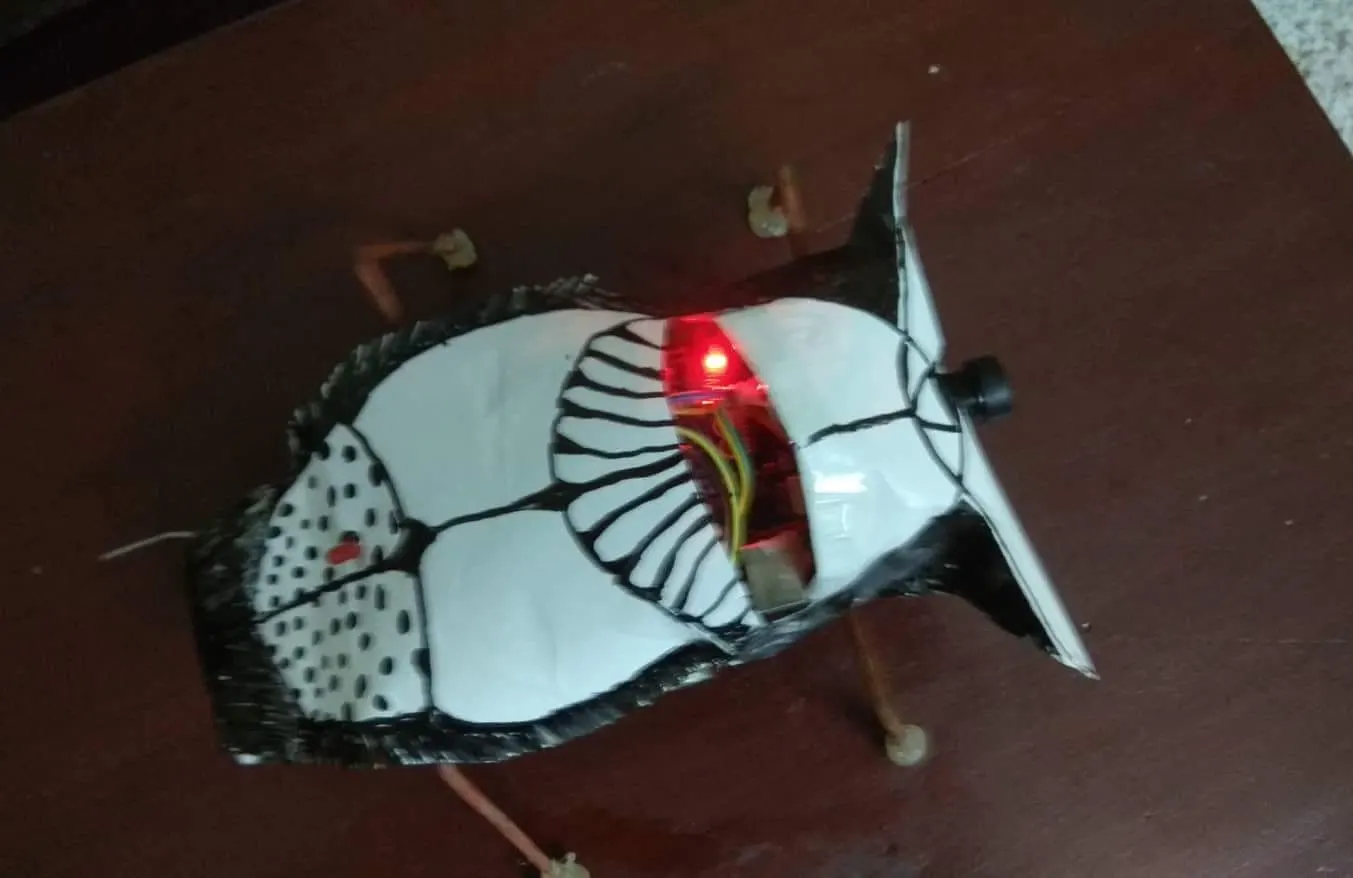
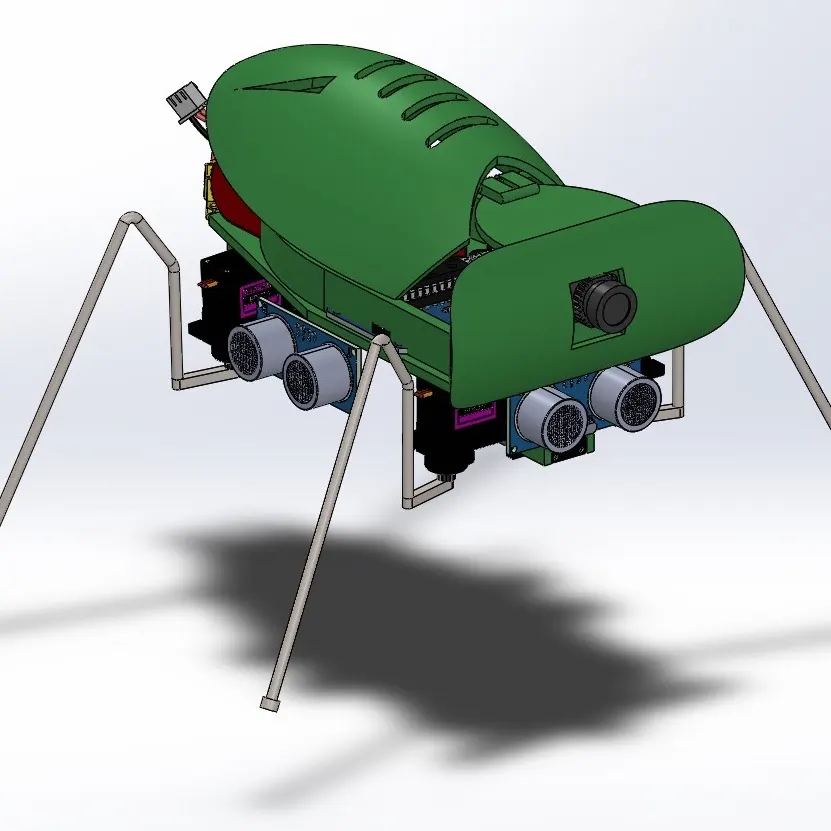
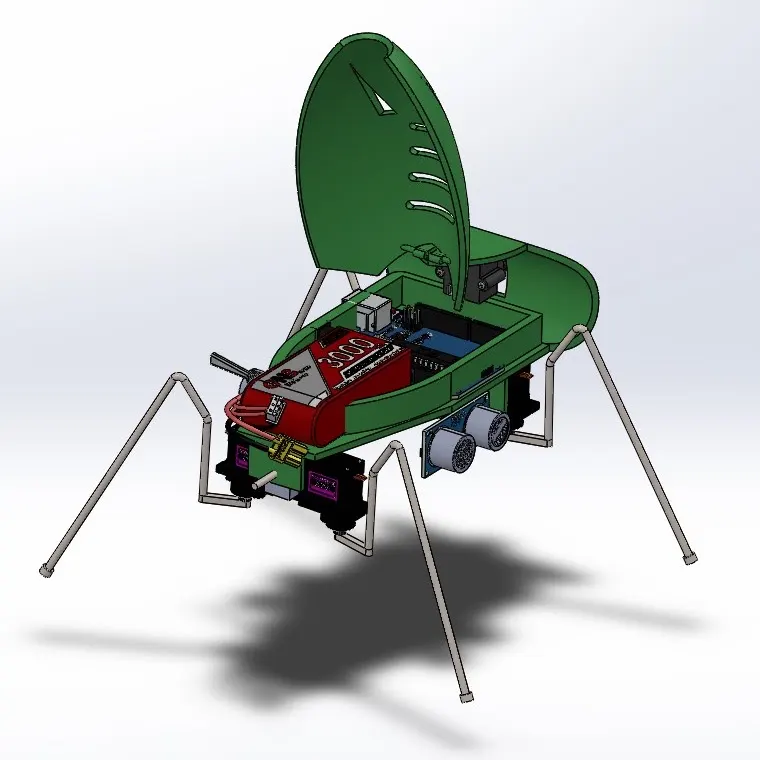
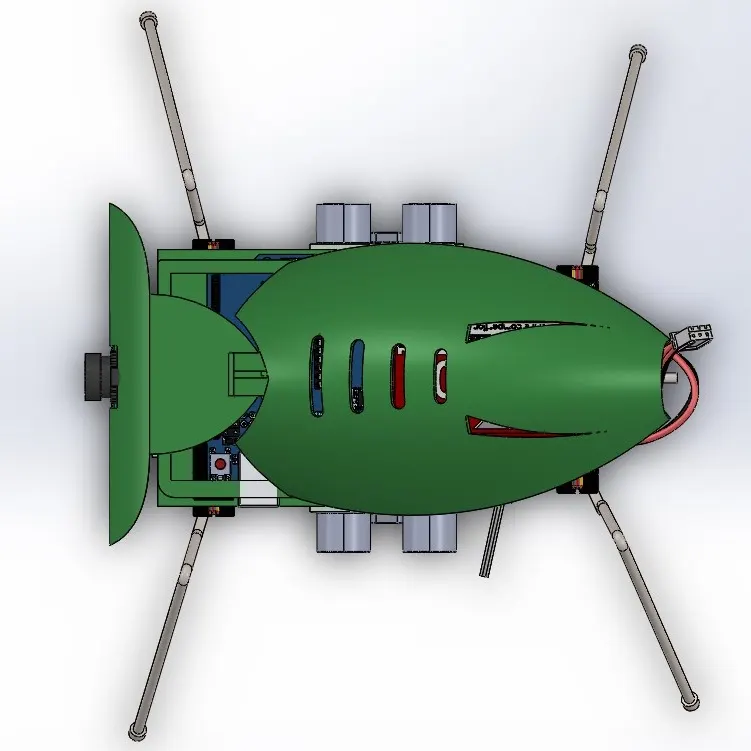
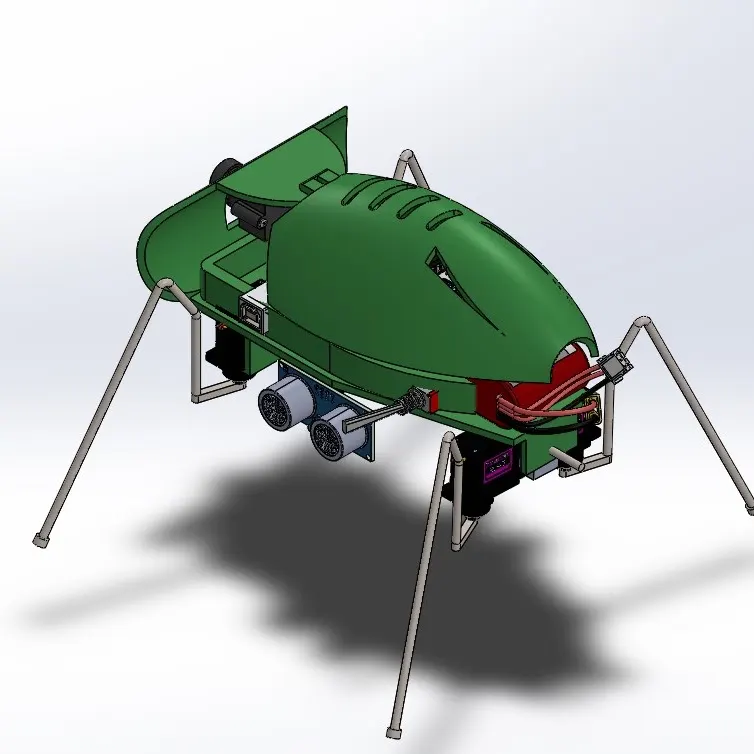
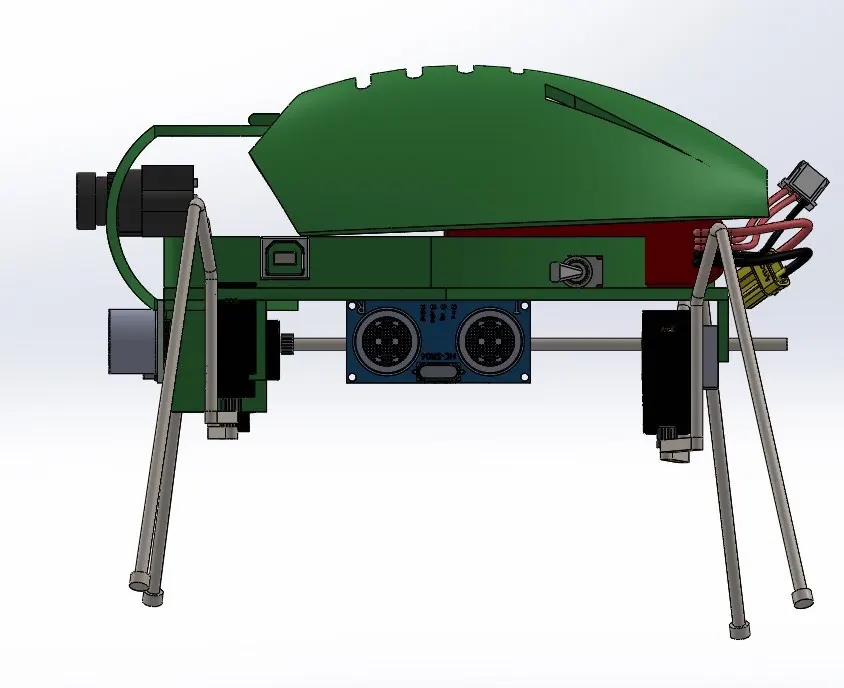
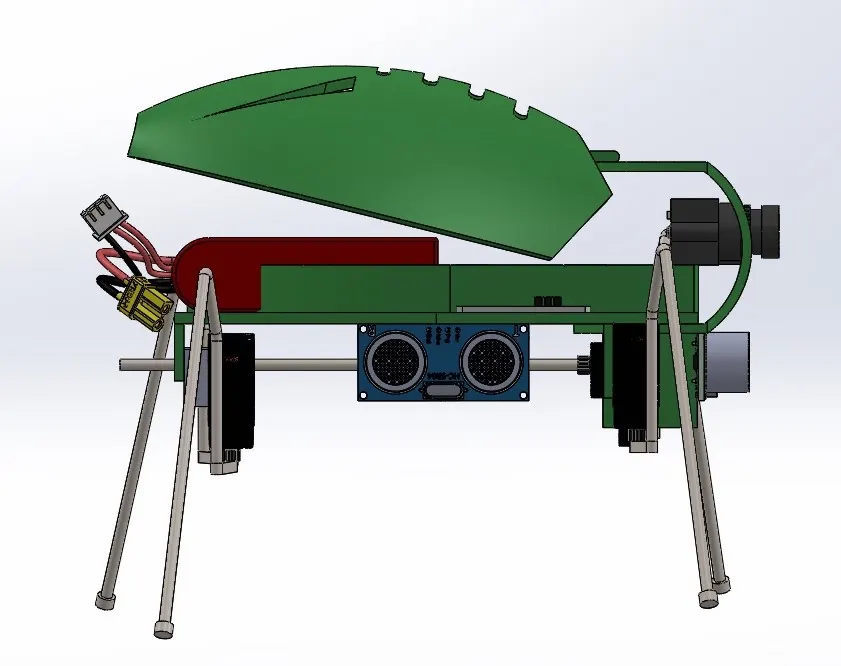
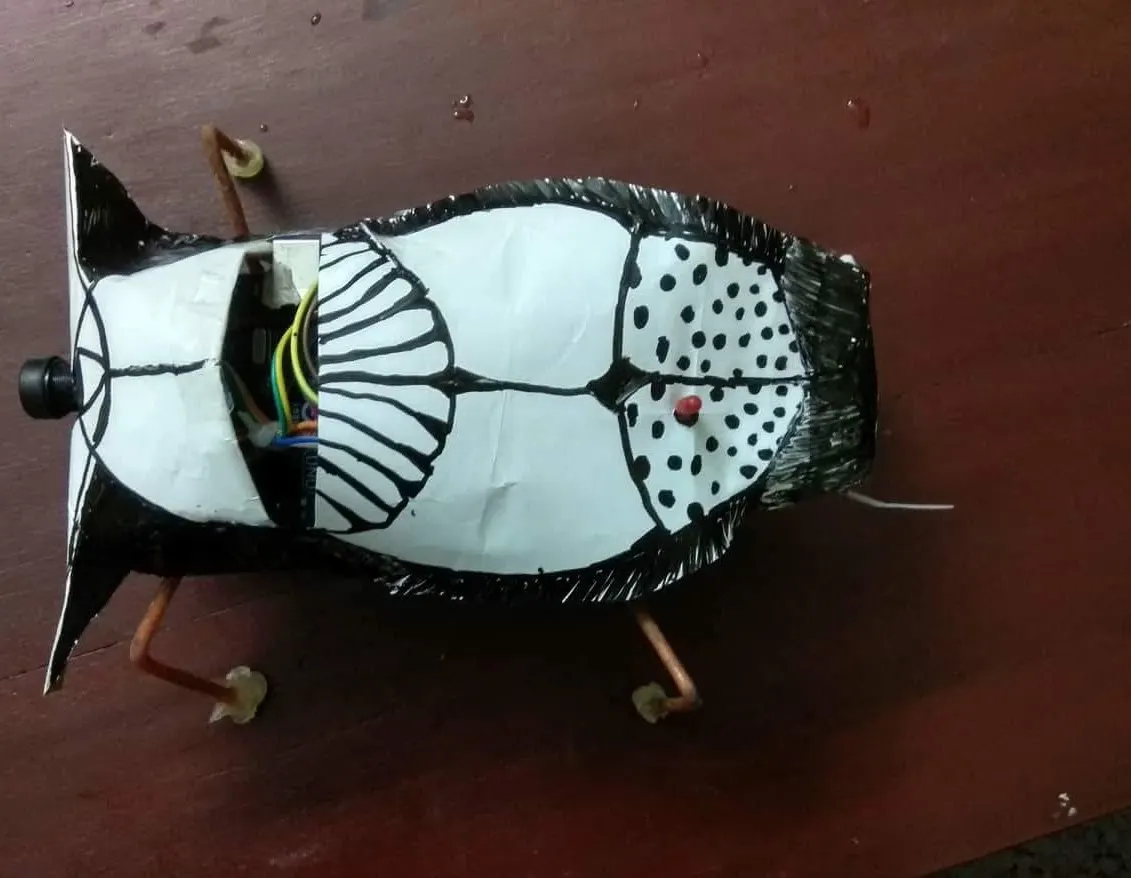
This work proposed to Design and Implementation of a Quadrupedal Insect Robot to study quadrupedal locomotion and surveillance of the unreachable surface terrain. This four-legged mobile robot has intelligent sensing and decision-making capabilities. Multiple sensors with embedded knowledge bases and learning capabilities are used in a novel approach towards environmental perception and reaction. These sensors continuously monitor the environment as well as their own operating parameters. This robot has the ability to function at varying degrees of intelligence made possible by an object-oriented architecture with embedded intelligence at various levels. Each of the four legs has three degrees of freedom, i.e. Our insect robot has a total of 5 servo motors on its four legs. It can walk and turn, and also can sense the obstacle distance around it. It responds to light, based on prevailing environmental conditions.
The center of the polygon is considered as the robots center of mass, indicated the green point
The number one to five indicates a predefined set of leg position.
If a robot has k legs the number of possible events N will be:
In case of a Quadrupedal walking insect robot (k=4) the number of possible events is N=(2k-1)! = (2*4-1)! = 7! = 5040
Here we try to move of legs in between (x) signs of the figure.
Front-Right & Back-left legs are synchronizing with the shaft clockwise rotation.
Front-Left & Back-Right legs are synchronizing with the shaft anticlockwise rotation.
Working Duration: February 2018- July 2018
Team#
- Joydeep Majumder
- Sajjad Hossain
Video
Gallery
Originally documented on the Ahsan’s Lab website.